|
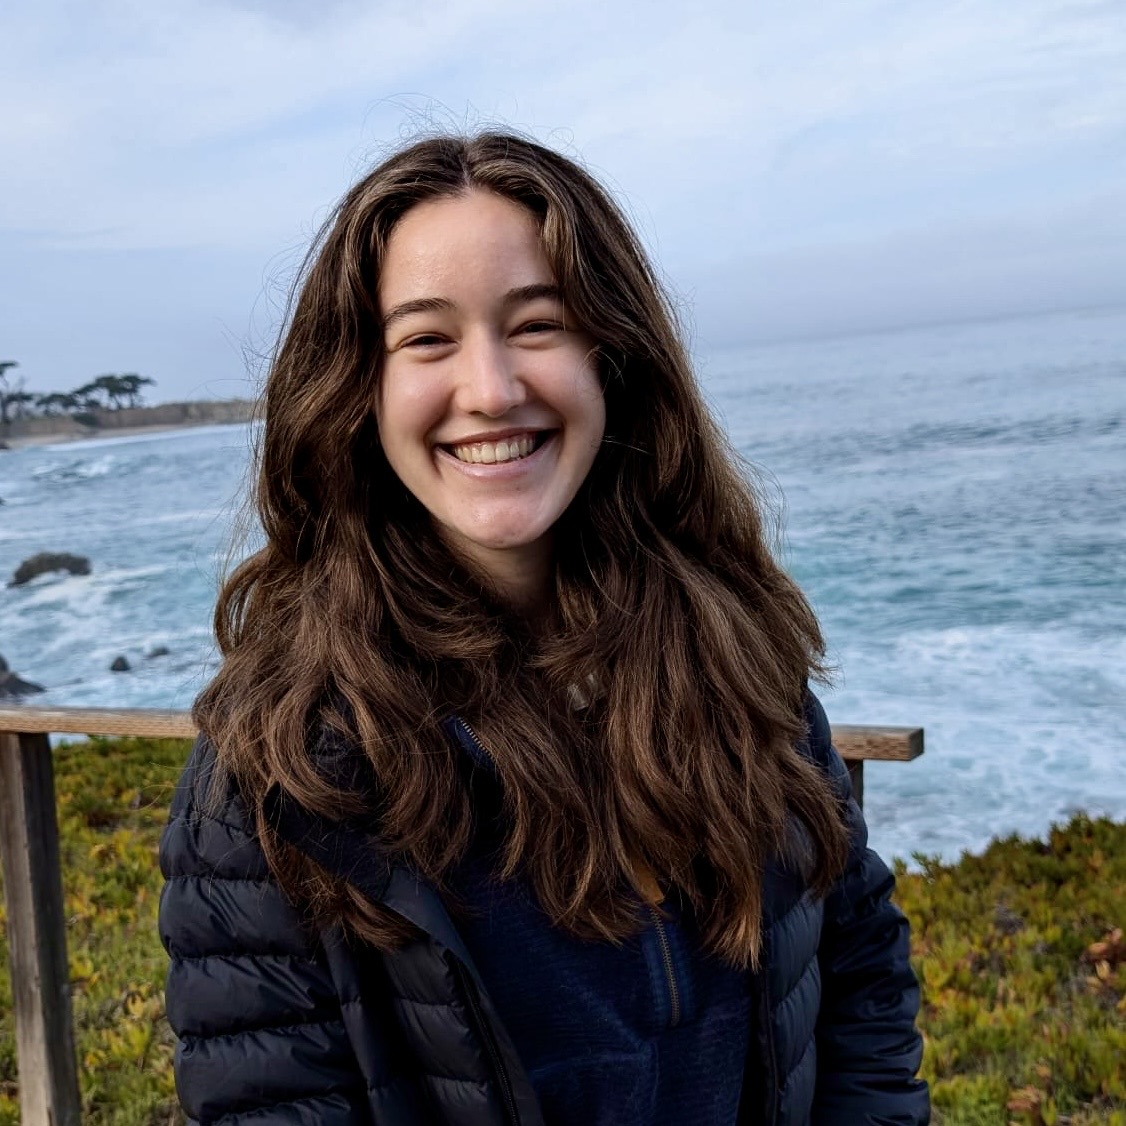
Alison Bartsch I am a Senior Computer Vision and Machine Learning Applied Scientist at Dandy. I recieved my PhD in Mechanical Engineering at Carnegie Mellon University's Mechanical and AI Lab (MAIL) with a focus on using machine learning for complex and dexterous robotic tasks, such as deformable object manipulation. I recieved my BS in Aeronautics and Astronautics at Stanford University, and was an undergraduate researcher in the Autonomous Systems Lab (ASL). Outside of my research, I have a passion for baking, collecting/propagating rare tropical plants, and playing/watching soccer. |
|
Research |
|
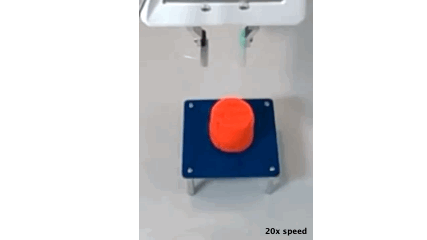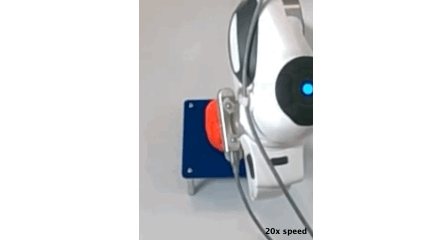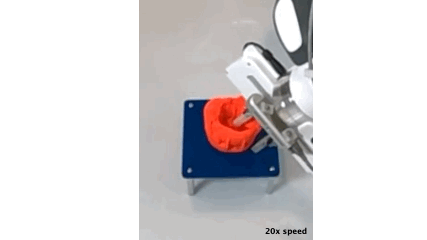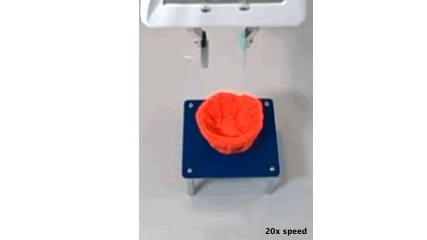
PinchBot: Long-Horizon Deformable Manipulation with Guided
Diffusion Policy
Alison Bartsch, Amir Barati Farimani Under Review, 2026 Project Page / Paper A robotic pinch pottery framework with task progress-guided 3D diffusion policy with pre-trained point cloud embeddings. |
|
Planning and Reasoning with 3D Deformable Objects for Hierarchical
Text-to-3D Robotic Shaping
Alison Bartsch, Arvind Car, Amir Barati Farimani IEEE Robotics and Automation Letters (RA-L), 2025 Project Page / Paper A text-to-3D real-world robotic coarse-to-fine framework for creating shapes without ground truth 3D goals. |
|
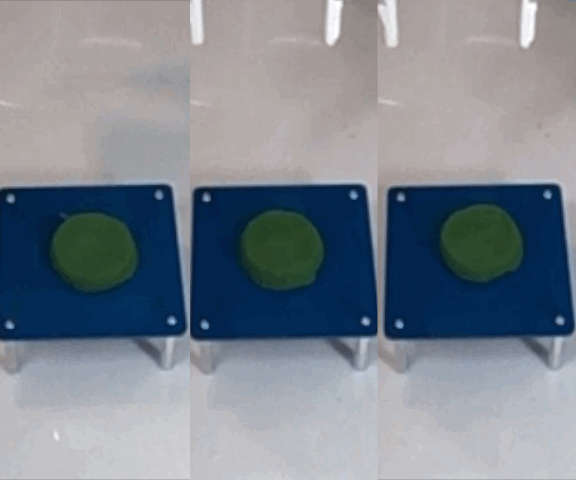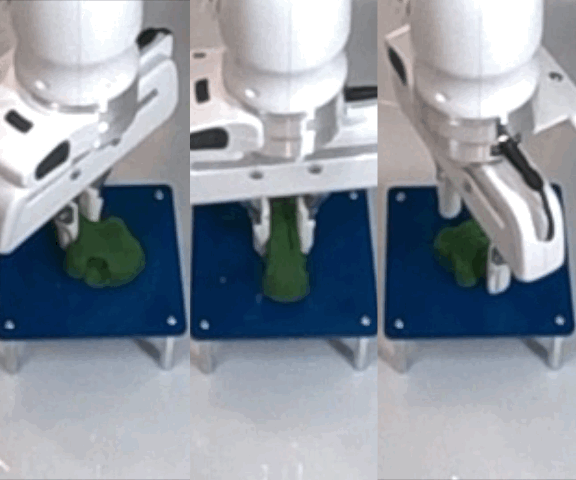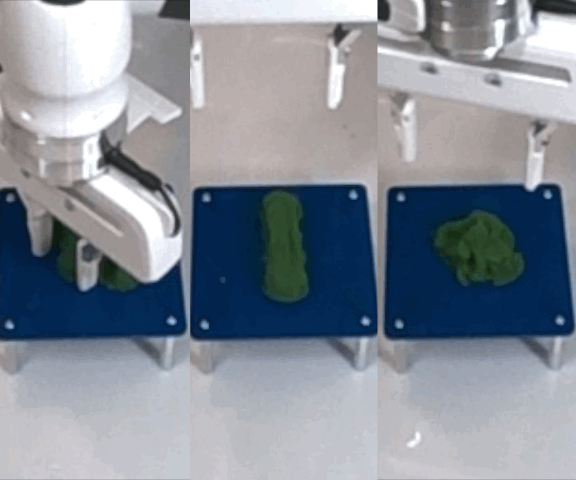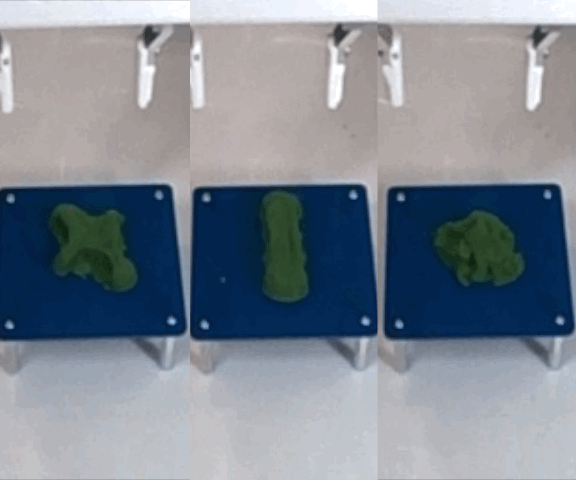
LLM-Craft: Robotic Crafting of Elasto-Plastic Objects with Large
Language Models
Alison Bartsch, Amir Barati Farimani IEEE Robotics and Automation Letters (RA-L), 2025 Project Page / Paper Leveraging the world knowledge of Large Language Models to generate coherent action sequences for 3D deformable object shaping. |
|
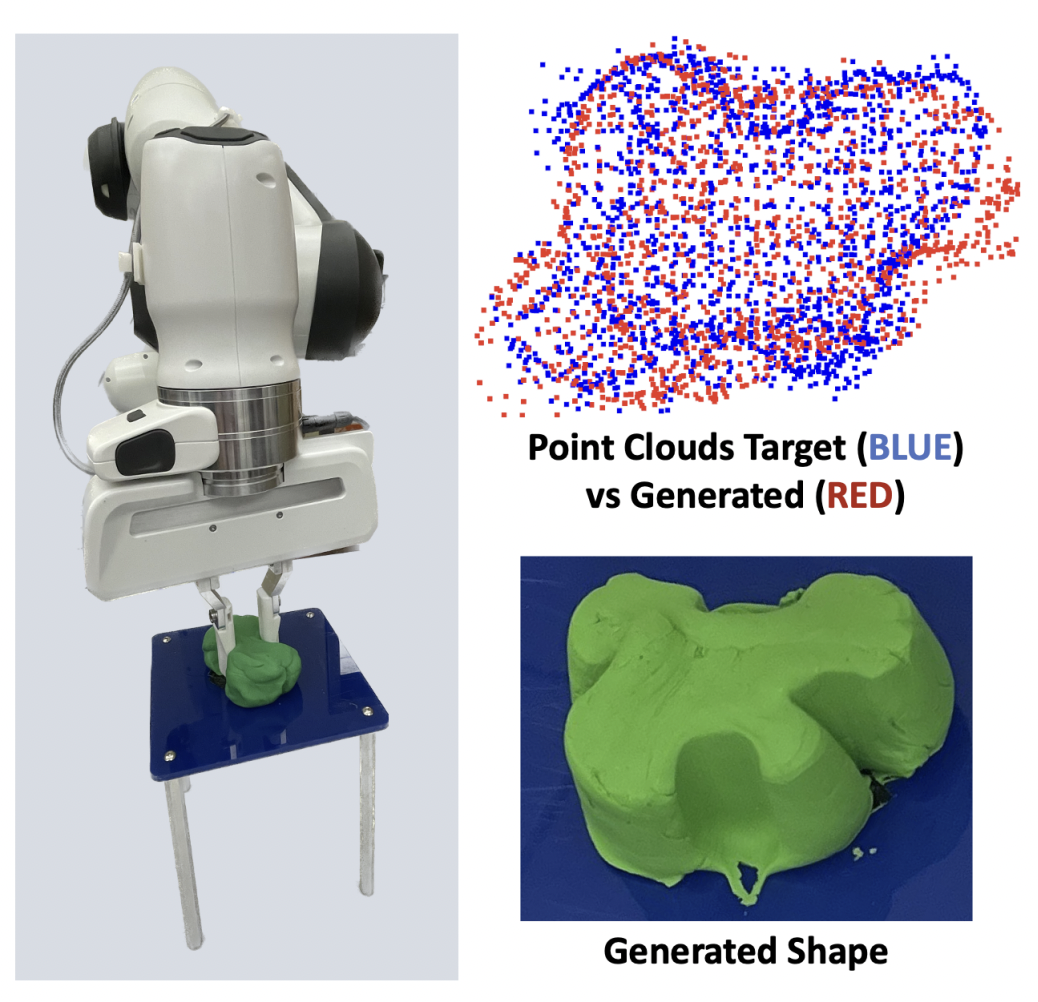
SculptDiff: Learning Robotic Clay Sculpting from Humans with Goal
Conditioned Diffusion Policy
Alison Bartsch, Arvind Car, Charlotte Avra, Amir Barati Farimani IEEE International Conference on Intelligent Robots and Systems (IROS), 2024 Project Page / Paper Goal-conditioned 3D diffusion policy with PointBERT point cloud embeddings for imitation learning for the autonomous clay sculpting task. |
|
SculptBot: Pre-Trained Models for 3D Deformable Object Manipulation
Alison Bartsch, Charlotte Avra, Amir Barati Farimani IEEE International Conference on Robotics and Automation (ICRA), 2024 Project Page / Paper PointBERT model pre-trained on the ShapeNet dataset provides a quality latent embedding of 3D geometrical features of clay relevant to predicting the deformable dynamics given a grasp action. |
|
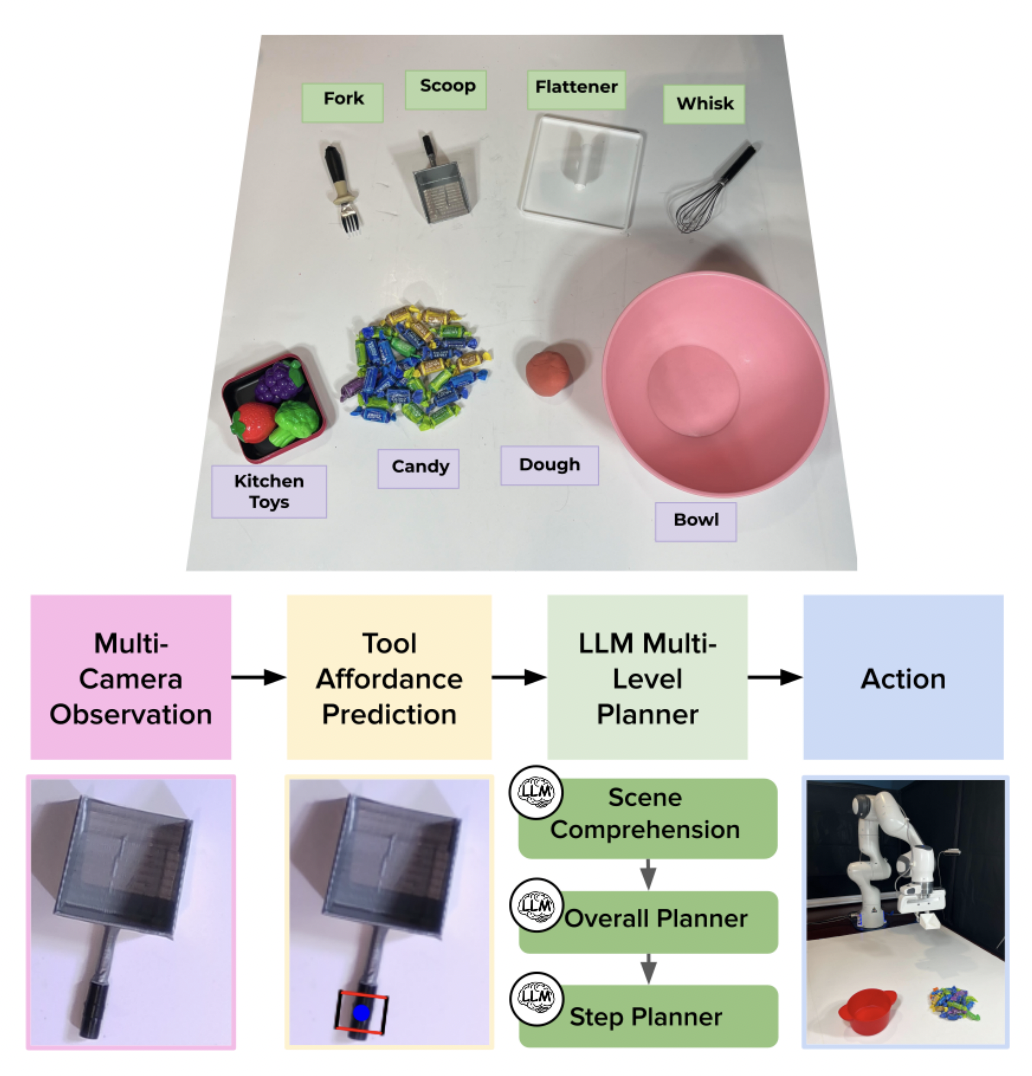
PLATO: Planning with LLMs and Affordances for Tool Manipulation
Arvind Car, Sai Sravan Yarlagadda, Alison Bartsch, Abraham George, Amir Barati Farimani Journal of Intelligent & Robotic Systems, 2026 Project Page / Paper Incorporating affordance predictions into an LLM planner pipeline for long-horizon tool use tasks. |
|
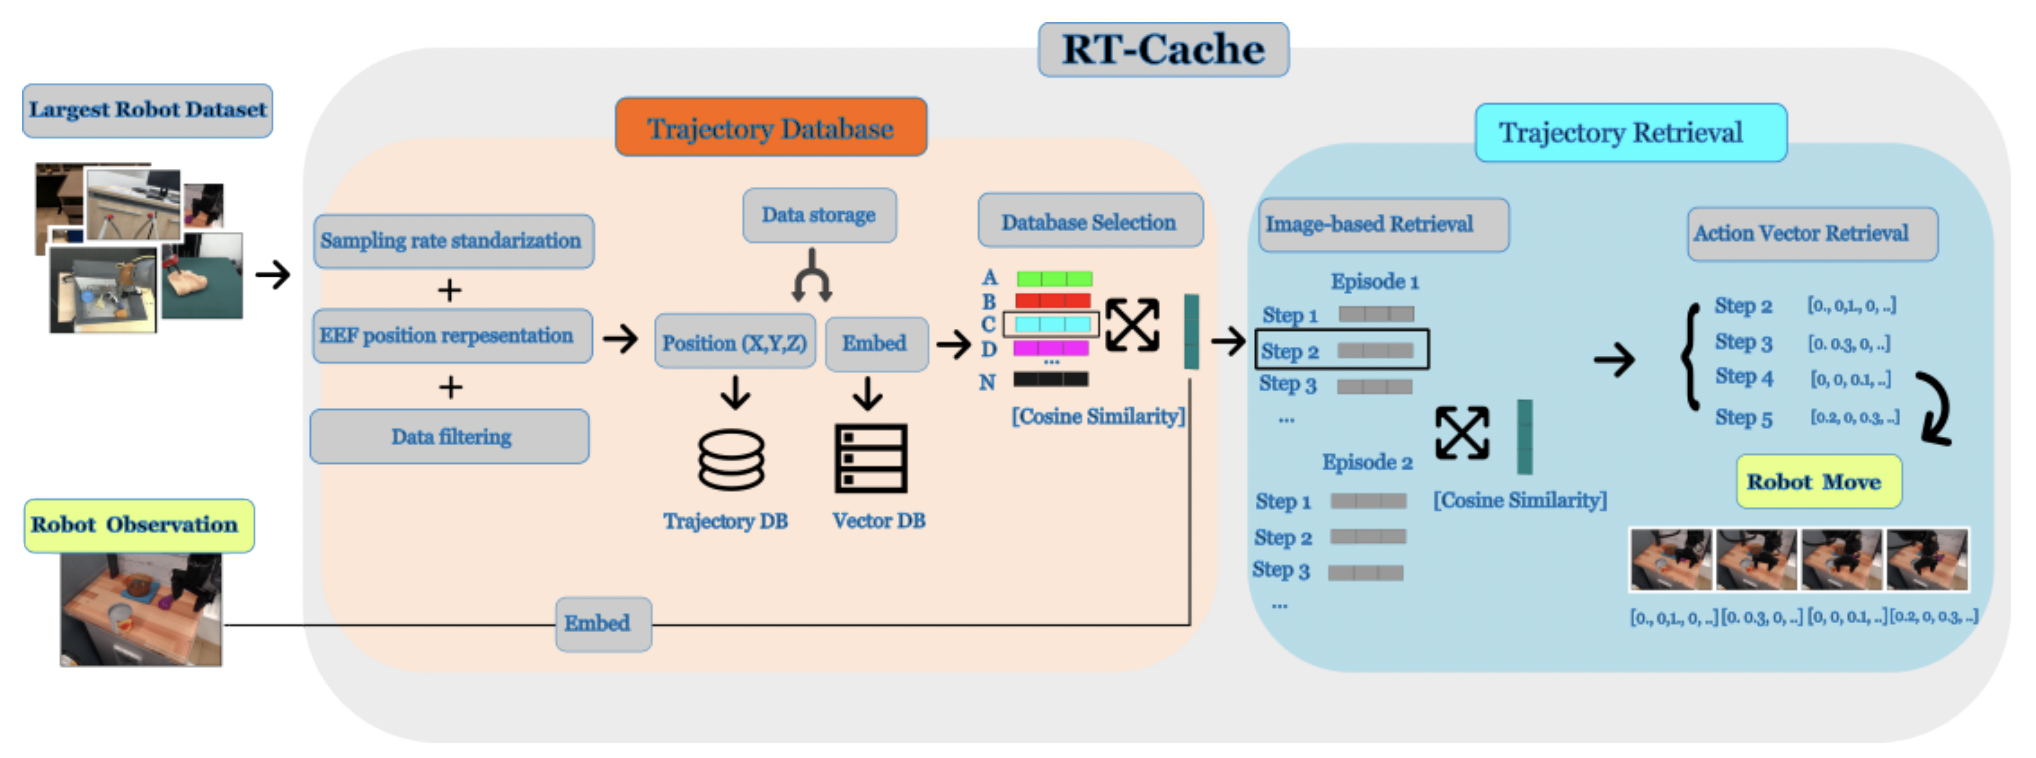
RT-cache: Efficient Robot Trajectory Retrieval System
Owen Kwon,Abraham George, Alison Bartsch, Amir Barati Farimani IEEE-RAS Humanoids, 2025 Paper Leveraging large pretrained Vision-Language-Action models' embedding space for fast lookup-based imitation. |
|
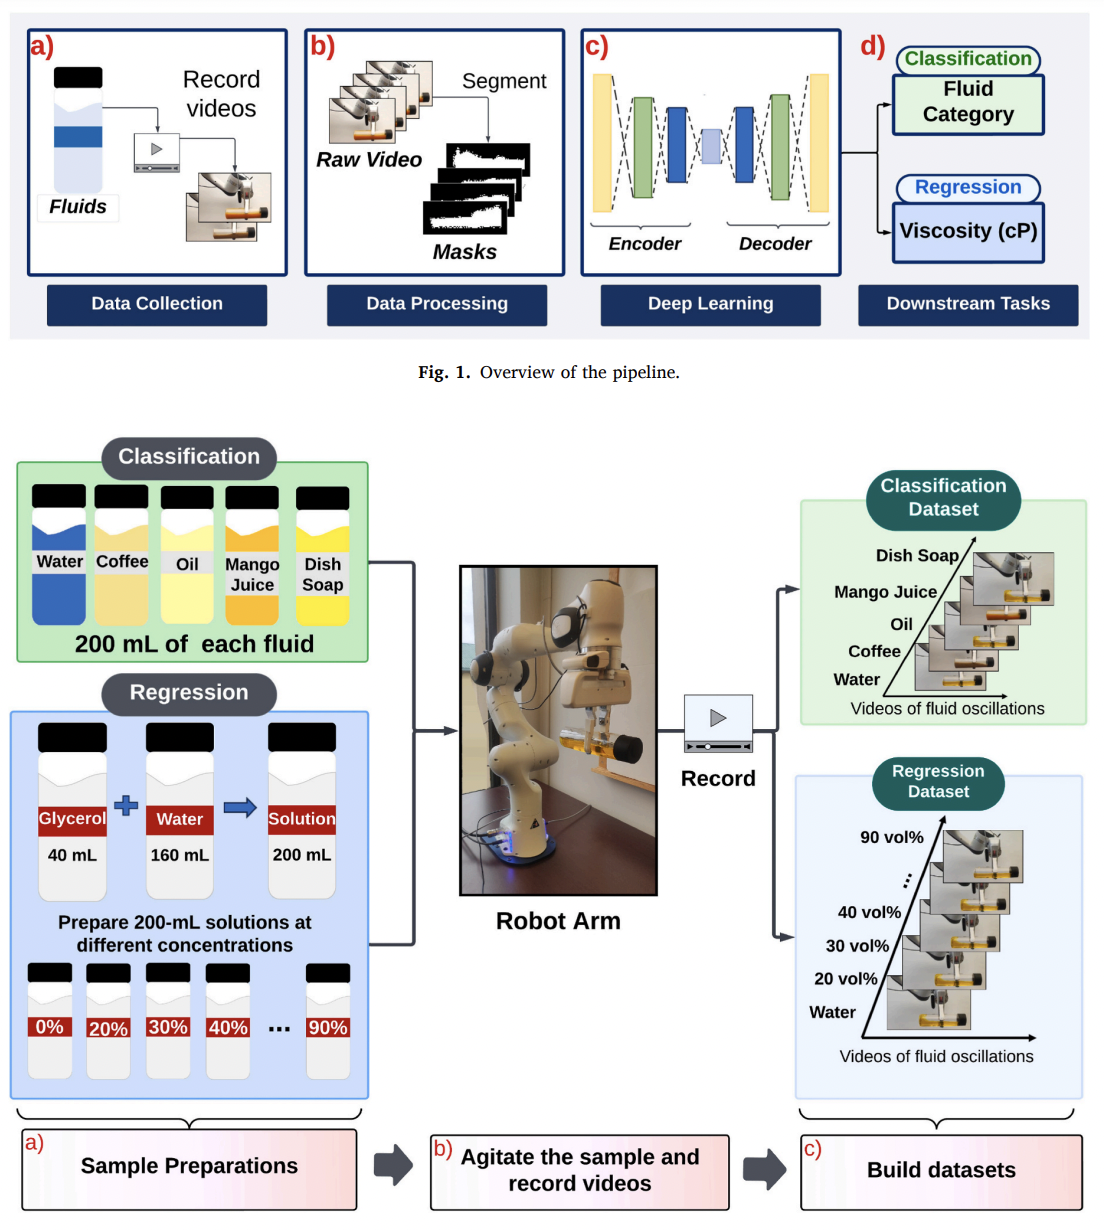
Fluid viscosity prediction leveraging computer vision and robot interaction
Jong Hoon Park, Gauri Pramod Dalwankar, Alison Bartsch, Abraham George, Amir Barati Farimani Engineering Applications of Artificial Intelligence, 2024 Paper Interactive perception framework for vision-based fluid viscosity prediction. |
|
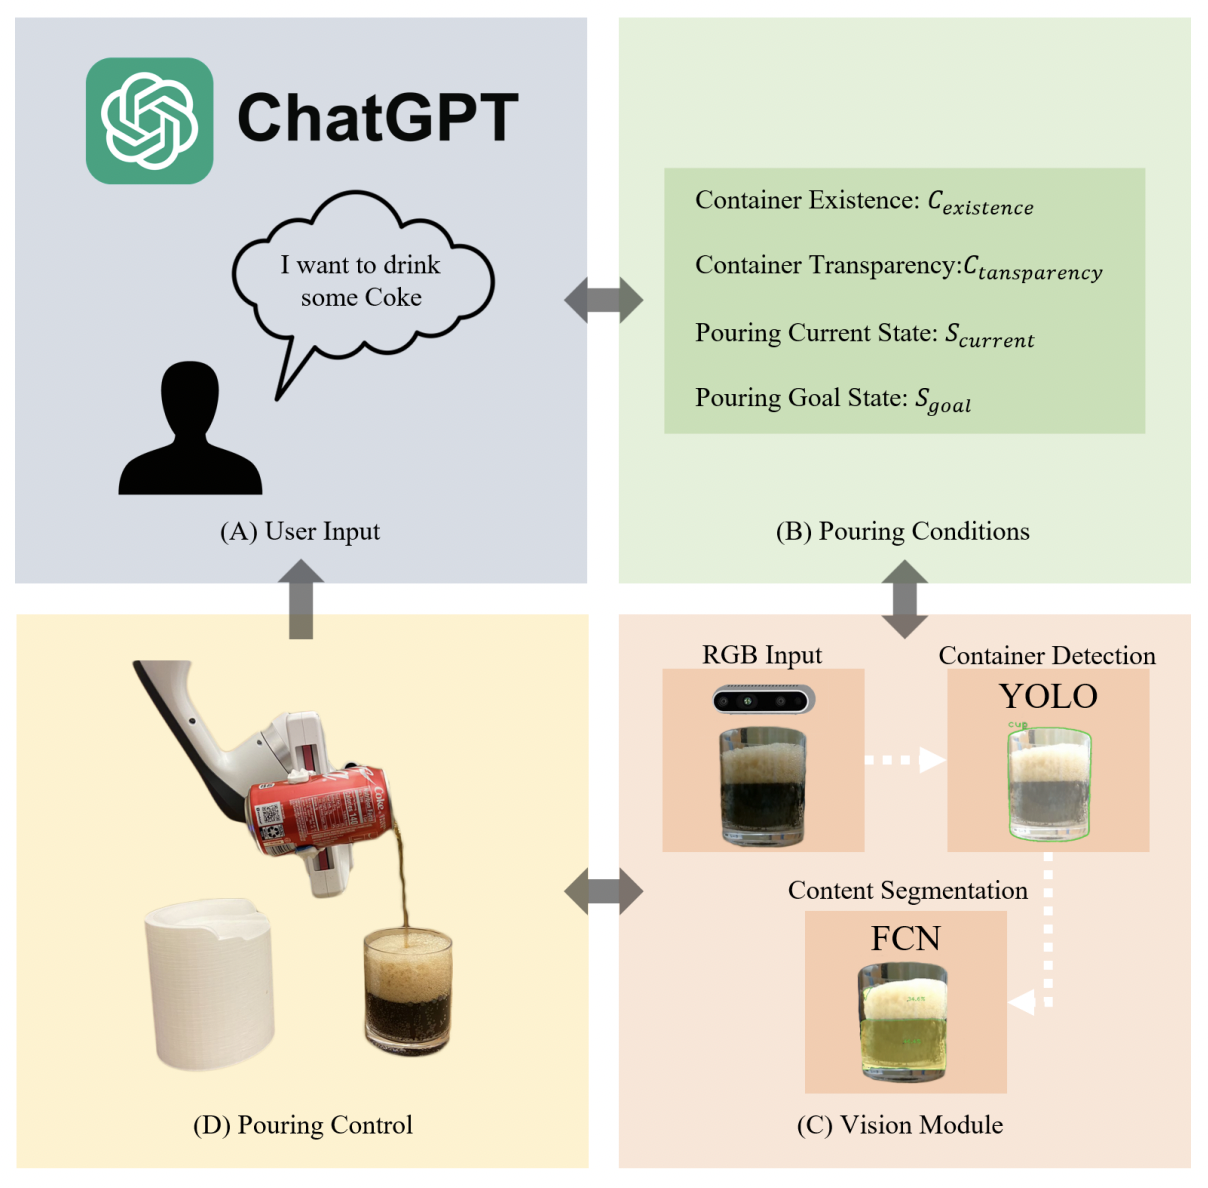
Pour me a drink: Robotic Precision Pouring Carbonated Beverages into
Transparent Containers
Feiya Zhu, Shuo Hu, Letian Leng, Alison Bartsch, Abraham George, Amir Barati Farimani preprint, 2023 Paper Vision-based autonomous pouring pipeline for transparent container detection, liquid segmentation, and foam formation prediction. |
|
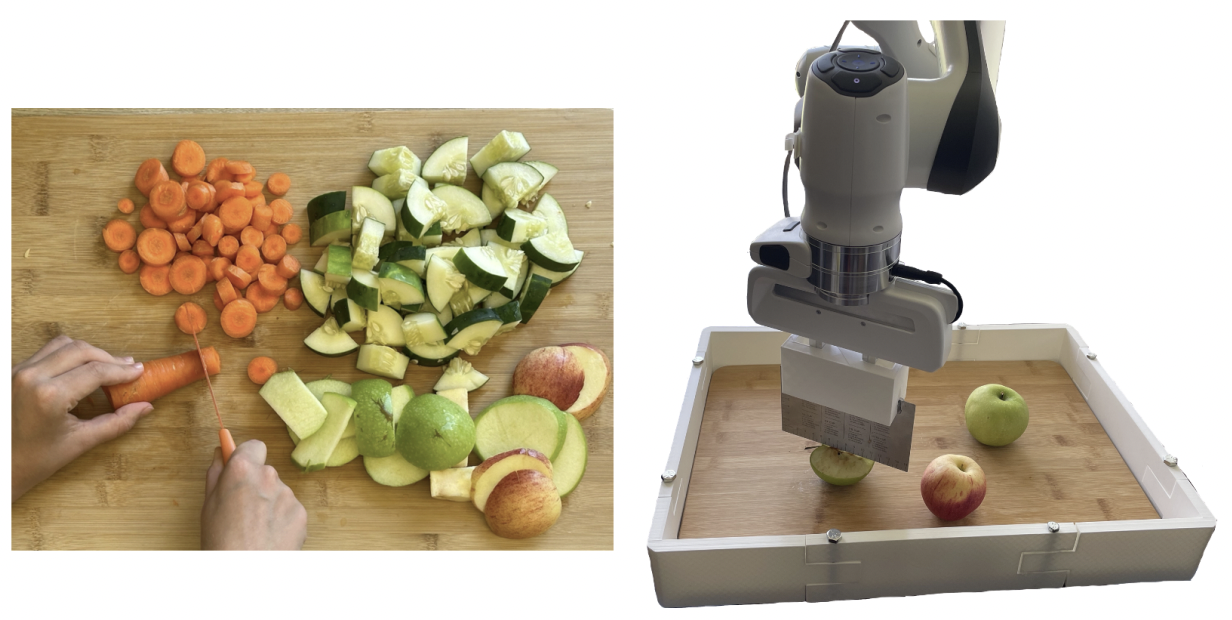
RoboChop: Autonomous Framework for Fruit and Vegetable Chopping
Leveraging Foundational Models
Atharva Dikshit*, Alison Bartsch*,Abraham George, Amir Barati Farimani preprint, 2023 Paper Leveraging foundational vision models SAM and YOLO for identifying fruits and vegetables in all states of chopped (whole to diced) for a fully autonomous chopping pipeline. |
|
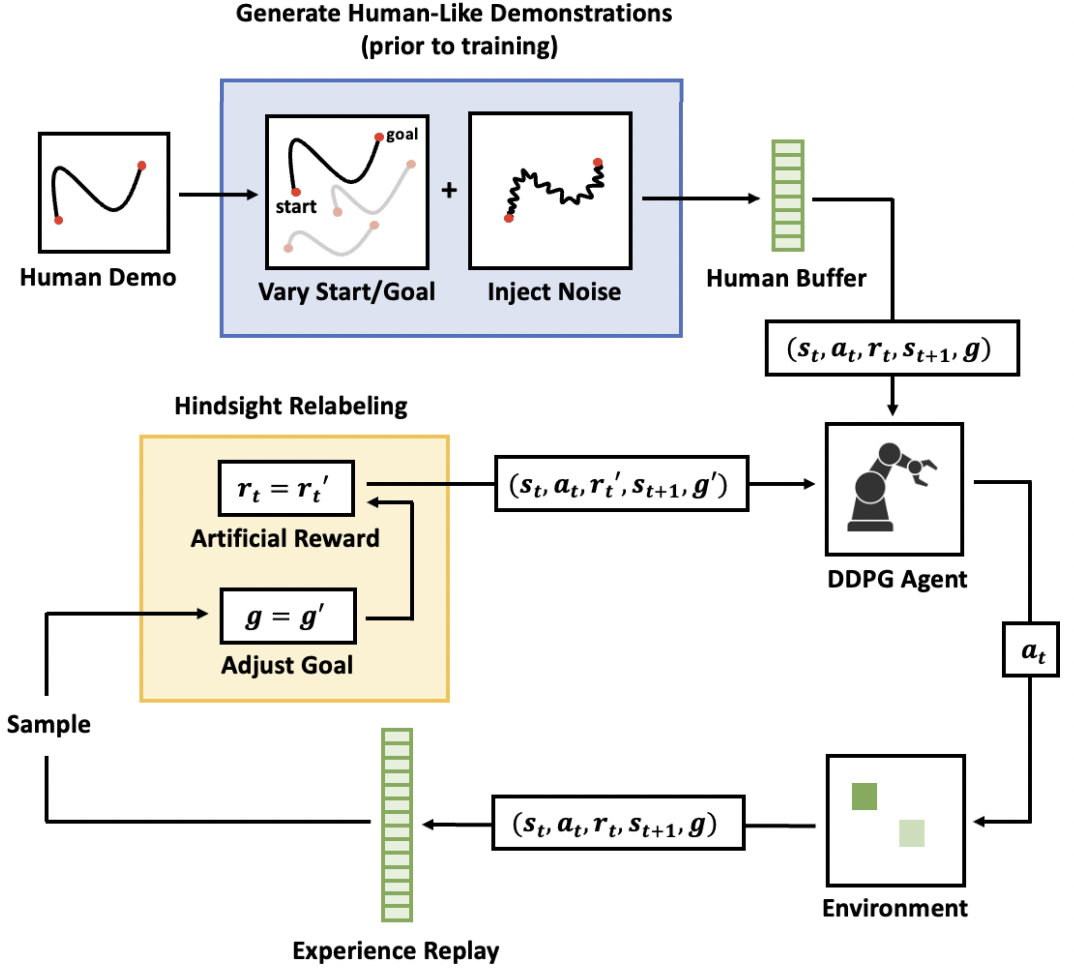
Minimizing Human Assistance: Augmenting a Single Demonstration for
Deep Reinforcement Learning
Abraham George, Alison Bartsch, Amir Barati Farimani IEEE International Conference on Robotics and Automation (ICRA), 2023 Paper An augmentation strategy that maintains the advantages of seeding RL with human demonstrations, while only requiring a single human demonstration. |
|
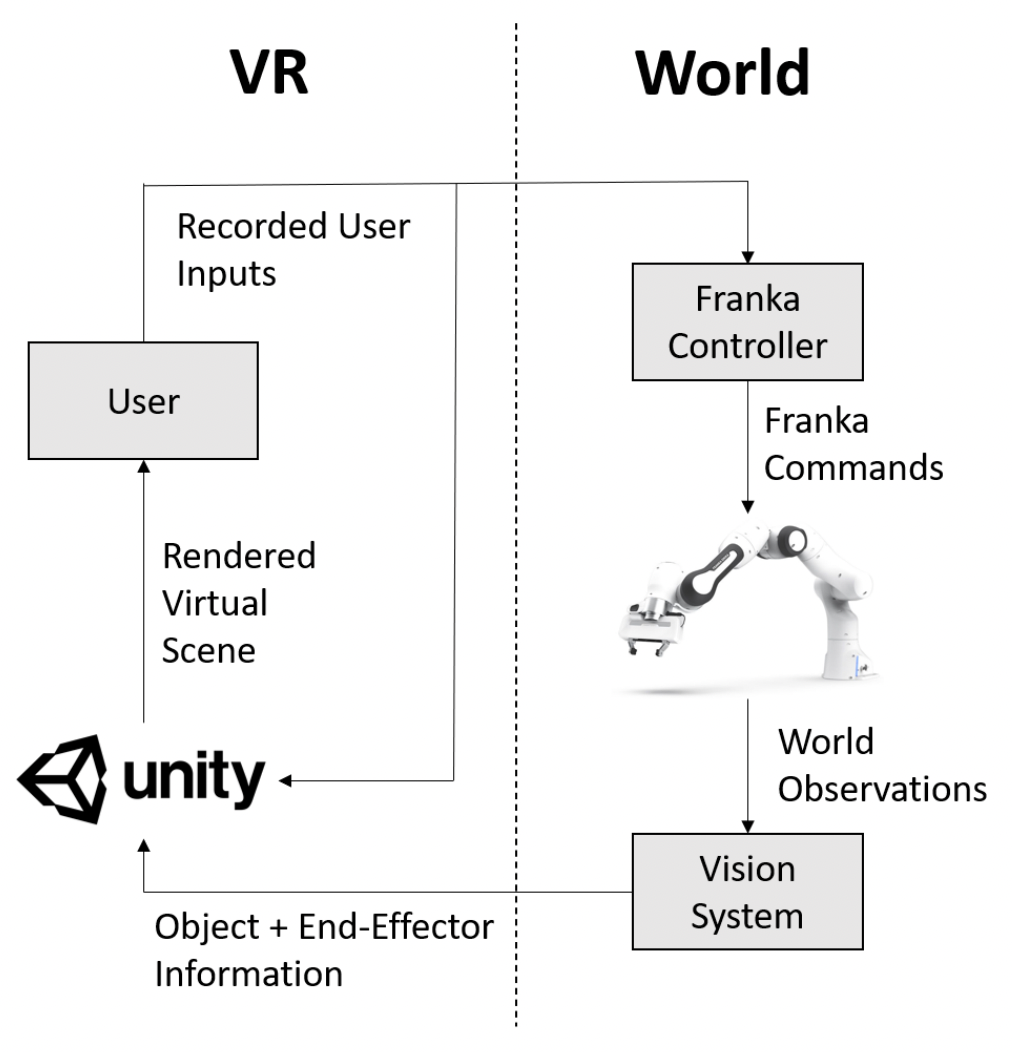
OpenVR: Teleoperation for Manipulation
Abraham George, Alison Bartsch, Amir Barati Farimani SoftwareX, 2023 Paper An open-source oculus-based teleoperation system for the Franka manipulator. |
|
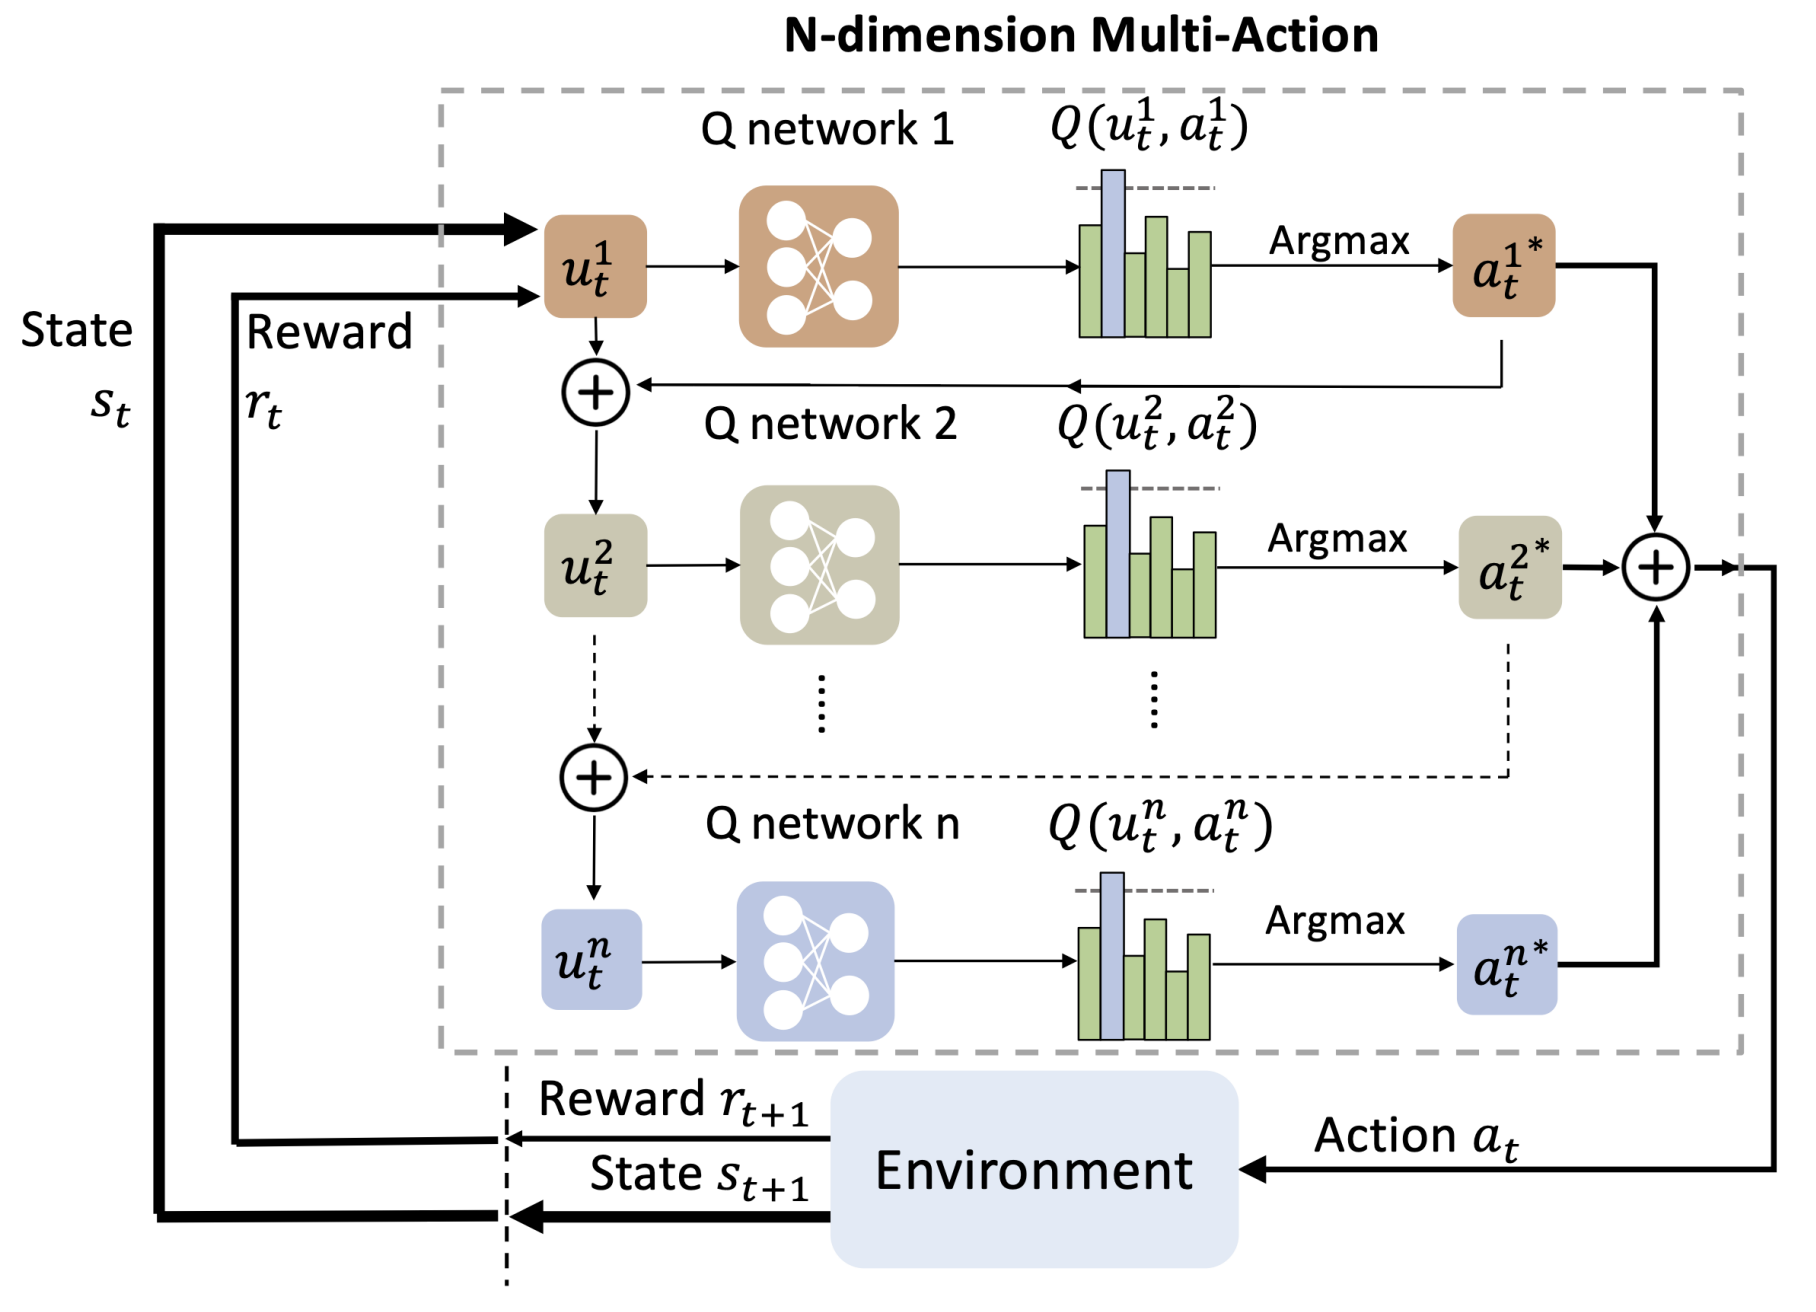
MAN: Multi-Action Networks Learning
Keqin Wang, Alison Bartsch, Amir Barati Farimani preprint, 2022 Paper Factorizing large N-dimensional action spaces into N 1-dimensional action spaces speeds up and improves policy learning for Deep Q-Learning. |
Education |
|
BS Aeronautics & Astronautics @ Stanford University. 2017-2021
PhD Mechanical Engineering @ Carnegie Mellon University. 2021-2025 |
Awards |
|
CMU Mechanical Engineering Shaw Fellowship, 2024. In recognition of academic excellence.
CMU Engineering Dowd Research Fellowship, 2023. In recognition of cutting-edge research. |
|
This template is taken from Jon Barron's website's source code |